How to Read an FFT Spectrum: Five Vibration Signatures Every Mechanic Should Know
How to read an FFT vibration spectrum: unbalance (1x), misalignment (2x and axial 1x), mechanical looseness (harmonics), bearing defects (BPFO, BPFI, BSF, FTF). Criteria per the SKF guide.
An FFT spectrum shows the frequencies at which a machine vibrates and at what amplitude. Reading starts with running speed, 1x. Per the SKF guide: unbalance gives a high 1x without harmonics, misalignment a raised 2x and axial 1x, mechanical looseness a series of 1x or 1/2x harmonics, and a bearing defect peaks at BPFO, BPFI, BSF and FTF.
What FFT is and where to start
FFT (Fast Fourier Transform) converts a vibration signal in time into a frequency spectrum. Instead of a complex waveform, the engineer sees individual peaks, each with a likely source.
Before looking for a fault, SKF recommends collecting the basics:
- Running speed (1x). Find it first: other peaks are judged as its multiples (2x, 3x and up) or as non-synchronous.
- Measurement type. Velocity, acceleration, displacement or acceleration enveloping. An enveloped signal, for example, points to bearings or gear teeth.
- Sensor position. Horizontal, vertical, axial, in the load zone. Sensor response depends on mounting location.
- Machine design. Bearing type (number or designation), coupling or belt, number of vanes and teeth.
The overall vibration level is judged against standards such as ISO 10816-3; the spectrum is used to find the cause.
Five signatures: summary table
| Condition | Spectrum sign (per SKF) | How to confirm |
|---|---|---|
| Normal | No pronounced peaks other than a small 1x; no growth between readings | Trend, comparison with baseline |
| Unbalance | High radial 1x, harmonics below 15 % of 1x | Phase: about 90° between horizontal and vertical |
| Misalignment | High 2x, high axial 1x | Phase: about 180° shift across the coupling |
| Mechanical looseness | Three or more 1x or 1/2x harmonics (2x–10x) above 20 % of 1x | Phase, inspection of mounting |
| Bearing defect | Peaks at BPFO, BPFI, BSF, FTF; in the late stage a "hump" in the high frequency range | Acceleration enveloping, time waveform |
Equipment covered in this article
Artesis e-MCM — Online Sensorless Motor Monitoring
Online sensorless electric motor monitoring with AI and digital twin
1. Normal
A small 1x peak is always present because the rotor turns. A healthy machine has no other pronounced peaks and no broadband rise in noise. "Normal" means little without a baseline: what matters is that amplitudes do not grow from one reading to the next.
2. Unbalance: 1x dominates
Unbalance means the rotor's mass centerline does not coincide with its geometric centerline. SKF distinguishes static, couple and dynamic unbalance; in practice most unbalance is dynamic.
Signs per SKF:
- single frequency vibration at 1x (once per revolution), sinusoidal;
- amplitude is the same in all radial directions;
- usually no harmonics of 1x unless the unbalance is severe;
- amplitude increases with speed.
SKF criterion: if radial 1x is high and harmonics (except vane passing) are below 15 % of 1x, unbalance is possible. If the signal has significant harmonics above 1x, the cause is most likely not unbalance.
Typical causes: material buildup or erosion on impeller vanes, a thrown balance weight, assembly errors after repair.
3. Misalignment: 2x and axial 1x
Misalignment occurs when the centerlines of connected shafts, couplings and bearings do not coincide. SKF distinguishes angular (shafts joined at an angle) and parallel (centerlines parallel but offset) misalignment.
Signs and SKF criteria:
- raised radial 2x when the machine has a coupling or belt;
- raised axial 1x;
- with severe misalignment, harmonics from 2x to 10x may appear.
Coupling assessment by the ratio of 2x to 1x:
| 2x relative to 1x | SKF assessment |
|---|---|
| Below 50 % | Usually acceptable, the coupling can run for a long time |
| 50–150 % | Coupling damage is probable |
| Above 150 % | Severe misalignment, schedule repair as soon as possible |
Phase. Angular misalignment gives about a 180° axial phase shift across the coupling; parallel misalignment gives it in the radial direction. A bearing cocked in its housing also produces considerable axial vibration, and axial phase readings help tell it apart from misalignment.
Causes per SKF: cold alignment that ignores thermal growth, coupling assembly errors, an uneven or settling foundation. So alignment done at installation can drift over time.
4. Mechanical looseness: a series of harmonics
Mechanical looseness is insufficient stiffness or an improper fit: a machine loose on its mounting, a cracked frame or support, a loose component, excessive bearing seat clearance.
Signs per SKF: a long string of running speed harmonics or 1/2 running speed harmonics at abnormally high amplitude. The harmonics may be disorganized, for example 2x, 3x, 4x, 5x or 3x, 3.5x, 4x, 5.5x. Harmonic amplitude usually falls with frequency, except 2x in the vertical direction.
SKF criterion: if there are three or more synchronous or 1/2 synchronous multiples in the 2x–10x range with amplitudes above 20 % of 1x, mechanical looseness is possible. For a rigidly connected machine with no coupling or belt, a high radial 2x also points to looseness.
The danger of looseness is that a part can come off and cause secondary damage.
5. Rolling element bearing defects: BPFO, BPFI, BSF, FTF
A rolling element bearing has four calculated defect frequencies:
| Frequency | Component | Formula (SKF) |
|---|---|---|
| BPFO | Outer race | (n/2)·(RPM/60)·(1 − (Bd/Pd)·cos φ) |
| BPFI | Inner race | (n/2)·(RPM/60)·(1 + (Bd/Pd)·cos φ) |
| BSF | Ball spin | (Pd/2Bd)·(RPM/60)·(1 − (Bd/Pd)²·cos² φ) |
| FTF | Cage | (1/2)·(RPM/60)·(1 − (Bd/Pd)·cos φ) |
Here n is the number of rolling elements, Bd the ball diameter, Pd the pitch diameter and φ the contact angle. The ball defect frequency is by definition 2 × BSF, because a defect on a ball strikes both the outer and inner race during one rotation. When a spectrum peak matches a calculated frequency, the defect is sought in that component.
What SKF points out:
- Bearing defect frequencies are much higher and their amplitudes much lower than those of unbalance and looseness. ISO overall severity charts were not developed for detecting early bearing degradation.
- In the early stage a defect may not be visible in a normal velocity or acceleration spectrum: impacts are weak and masked by rotational vibration. For the early stage, acceleration enveloping is used to bring out repetitive impacts.
- Velocity and acceleration measurements are good at showing the final stages, when, per SKF, less than 10 % of residual bearing life remains. In the late stage a wide "hump" appears in the bearing frequency range.
- The bearing is rarely the root cause. When a defect is found, SKF recommends looking for the cause: misalignment, unbalance, lubrication problems.
More on the stages in "4 stages of bearing failure".
Where an FFT spectrum alone falls short
Two limitations follow:
- Early bearing defects. A normal velocity or acceleration spectrum may not show them; enveloping or ultrasound is needed.
- Coverage. Online sensors go on critical machines, and the rest of the equipment is checked with a portable instrument on a route, with intervals between readings. A defect that develops between rounds can go unnoticed.
Other condition monitoring methods address both limitations; they complement vibration analysis rather than replace it.
SDT340 ultrasound: friction and impacts at an early stage
SDT340 is an SDT ultrasound instrument with two measurement channels: ultrasound 20–50 kHz and vibration 10 Hz – 10 kHz. Per SDT, ultrasound detects friction, impacting and turbulence earlier than other condition monitoring technologies. A recorded signal can be analyzed as an FFT spectrum and as a time waveform.
For bearings, a rise in ultrasound level indicates growing friction, including from under or over lubrication, before pronounced impacts appear. For condition-based lubrication SDT offers LUBExpert: it shows when to grease a bearing and when to stop.
Artesis e-MCM: motors without sensors on the machine
Artesis e-MCM analyzes the three-phase supply voltage and current of an electric motor and uses them to detect mechanical, electrical and process faults. No sensors are installed on the machine, so monitoring can cover motors that vibration routes do not reach. For route surveys on the same principle there is the portable Artesis AMT Pro.
How the methods work together
| Task | Method |
|---|---|
| Early signs of bearing friction and impacts, lubrication control | Ultrasound (SDT340, LUBExpert) |
| Continuous motor monitoring without installing sensors | Current and voltage analysis (Artesis e-MCM) |
| Confirming and classifying the fault: unbalance, misalignment, looseness, bearing | FFT vibration analysis, enveloping, phase |
Ultrasound and current analysis give the first signal; vibration analysis pins down what exactly is wrong. How to build such a program is covered in "What is equipment vibration diagnostics and where to start".
Which instrument to choose
- Ultrasound bearing and lubrication monitoring with a vibration channel — SDT340.
- Continuous sensorless monitoring of electric motors — Artesis e-MCM.
KEG TRK supplies SDT and Artesis equipment in Kazakhstan. Price on request.
Sources
- SKF USA Inc., J. Mais. Spectrum Analysis: the key features of analyzing spectra — sections 3–4 (analysis steps), 5 (misalignment), 6 (unbalance), 7 (looseness), 9 (rolling element bearings).
- SDT Ultrasound Solutions. Mechanical Condition Monitoring.
- SDT340 product page: ultrasound and vibration channel ranges.
- LUBExpert product page: ultrasound-guided lubrication.
- Artesis e-MCM product page: input signals and fault types.
Frequently asked questions
Equipment in this article
KEG TRK quotes prices and delivery times to Kazakhstan on request. We will prepare a commercial offer for your application.
Artesis e-MCM — Online Sensorless Motor Monitoring
Online sensorless electric motor monitoring with AI and digital twin
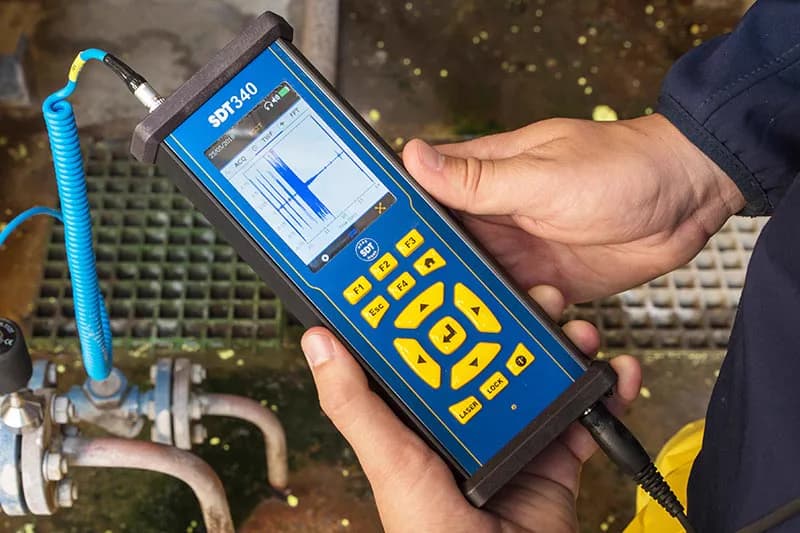
SDT340 - Advanced Ultrasound Detector
The most advanced ultrasound detector for collecting, analysing and trending data
Also in this article: LUBExpert — SDT Ultrasound Bearing Lubrication Assistant, SCOUT Series — portable vibration analyzers, System 1 — condition monitoring platform, 3500/42M Proximitor/Seismic Monitor, 330500 Series — Velomitor Velocity Sensor
Read also
6/23/2026
Why Vibration Analysis Alone Isn't Enough: SDT Ultrasound and Artesis Electrical Monitoring
Vibration analysis doesn't see everything. Here's what SDT 340 ultrasound, LUBExpert and Artesis e-MCM online motor monitoring add — and why they're installed alongside vibration, not instead of it.
6/30/2026
Integrated PdM on One Site: Artesis + Bently Nevada + SDT
Three KEG TRK pillars on one plant: Bently vibration on turbo-machinery, SDT ultrasound on routes, Artesis ESA on motors and generators — zone matrix, workflow and architecture.
6/30/2026
How to improve plant reliability in 5 steps: SDT + Artesis
No big-bang PdM: asset register, SDT quick wins, AMT Pro route, e-MCM on chronic assets, KPI governance.